Robotics · Georgia Tech
Rui Yan
Building robots for
the real world.
I work on practical, deployable robotic systems that bridge research and real-world industrial applications.
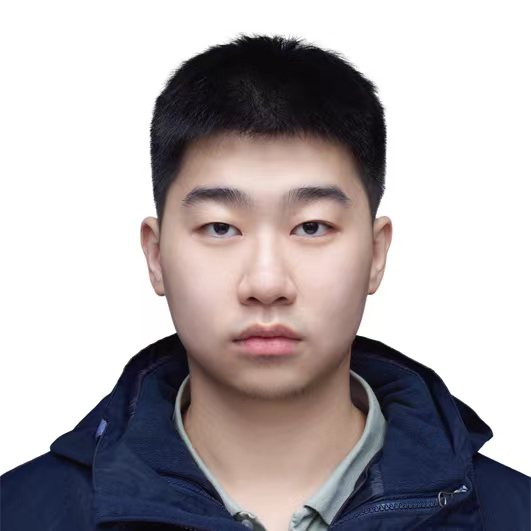
A little background
I am a first-year Ph.D. student in Robotics at Georgia Tech, advised by Prof. Ye Zhao. I received my M.S. in Electrical and Computer Engineering from UC San Diego, advised by Prof. Xiaolong Wang. I previously worked with Prof. Fei Liu and Prof. Tianshu Yu. I am interested in building practical and deployable robotic systems that bridge research and real-world industrial applications.
Latest news
-
Aug 2026
Started my Ph.D. in Robotics at Georgia Tech, advised by Prof. Ye Zhao.
-
Jun 2025
Gave a talk and presented a demo at the 1st RSS Workshop on Robot Hardware-Aware Intelligence.
-
Nov 2024
Started my M.S. in Electrical and Computer Engineering at UC San Diego.
-
Jun 2024
Graduated from Chongqing University.
Learning. Manipulation. Interaction.
Publications.
From ideas to systems
Selected projects.
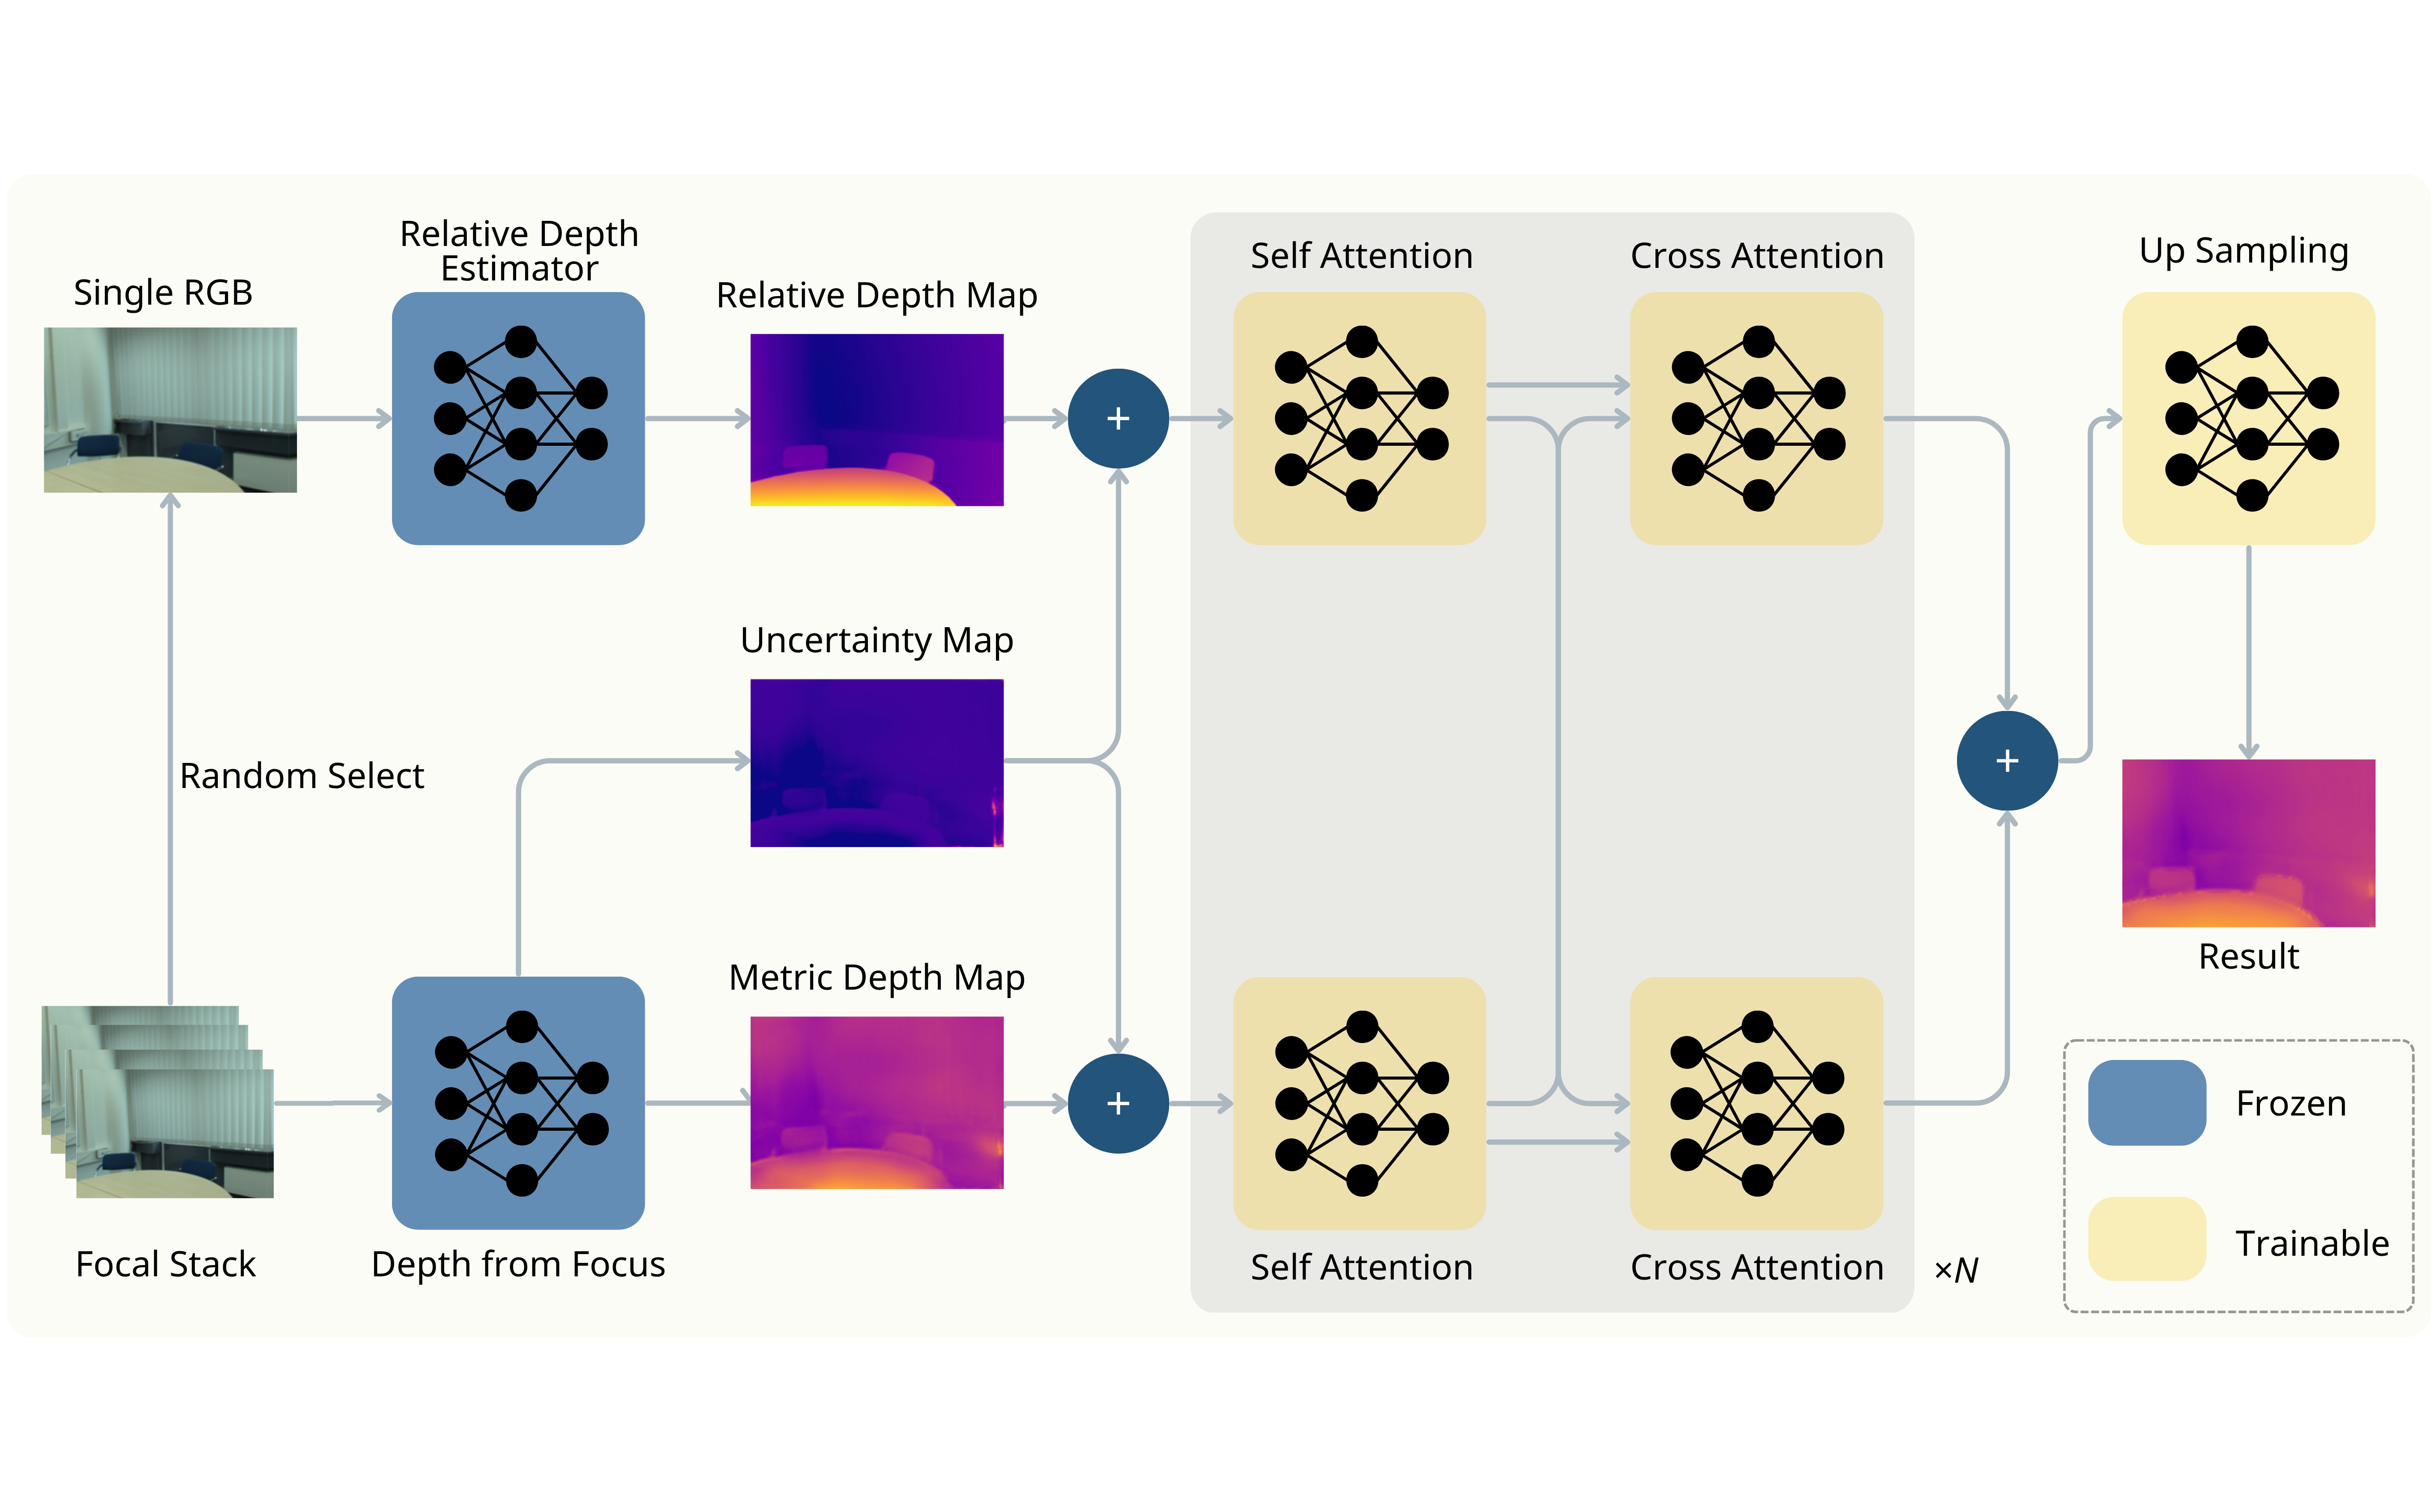
Attention-Driven Depth Fusion: Leveraging Focus and Single-Image Priors with Self-Cross Attention
We propose an end-to-end model that fuses a single RGB image and its defocus map using attention mechanisms to estimate depth. Instead of handcrafted fusion, it uses self- and cross-attention for uncertainty-aware refinement.
Beyond the publications
Experience & service.
Work experience
Jun 2023 - Dec 2023
Research Assistant at CUHKSZ, advised by Prof. Tianshu Yu
Jul 2021 - Aug 2021
Robot Engineer at NinboX Institute
Academic services
Conference Attendee
- CES 2026, Las Vegas
- CES 2025, Las Vegas
- RSS 2025, Los Angeles, California | Wednesday, June 25th, 2025
Journal Reviewer
- Currently NA
Rui Yan · Georgia Tech
Let’s connect.
ryan91@gatech.edu
Office · GTMI 377